


This is a fork of SymbolicAWEModels from July 2026 with the goal not to introduce any braking changes for at least a year.
StableAWEModels.jl is a compiler for mechanical systems, built for Airborne Wind Energy (AWE) modelling. It takes a structural description of a system — defined in Julia code or a YAML file — and compiles it into an efficient ODE problem using ModelingToolkit.jl.
 Define Components         Assemble             Compile            Simulate
┌──────────────────┐    ┌──────────────┐     ┌─────────────────┐     ┌────────────┐
│ Point, Segment,  │───▶│ System       │────▶│ SymbolicAWE     │────▶│ init!()    │
│ Wing, Winch, ... │    │ Structure    │     │ Model           │     │ next_step! │
│                  │    │              │     │ (symbolic eqs → │     │ sim!()     │
│ Julia or YAML    │    │ (resolves    │     │  ODEProblem)    │     │            │
│                  │    │  references) │     │                 │     │            │
└──────────────────┘    └──────────────┘     └─────────────────┘     └────────────┘
The first compilation is slow as ModelingToolkit generates and simplifies the symbolic equations. The result is cached to a binary file, making subsequent runs fast (seconds).
StableAWEModels provides building blocks for flexible mechanical systems:
- Point masses — static, dynamic, or quasi-static nodes
- Segment spring-dampers — with per-unit-length stiffness, damping, and drag
- Tethers — collections of segments controlled by a winch
- Winches — torque-controlled motors with Coulomb and viscous friction
- Pulleys — equal-tension constraints between segments
- Wings — rigid body quaternion dynamics with aerodynamic forces from the Vortex Step Method
- Groups — twist degrees of freedom for aeroelastic coupling
- Transforms — spherical coordinate positioning of components
These components can be combined to model a wide range of systems, from simple hanging masses to complex kite power systems with multiple tethers, bridles, and wings.
Install Julia using juliaup:
curl -fsSL https://install.julialang.org | sh
juliaup add 1.12
juliaup default 1.12
Create a project and add StableAWEModels:
mkdir my_project && cd my_project
julia --project="."
using Pkg
pkg"add StableAWEModels"
pkg"add GLMakie"using StableAWEModels
using StableAWEModels: Point
using GLMakie
using KiteUtils: init!, next_step!
StableAWEModels.copy_data()
set_data_path("data/base")
set = Settings("system.yaml")
set.v_wind = 0.0
# Define components using symbolic names
points = [
Point(:anchor, [0, 0, 0], STATIC; transform=:tf),
Point(:mass, [0, 0, -50], DYNAMIC; extra_mass=1.0, transform=:tf),
]
segments = [Segment(:spring, :anchor, :mass,
614600.0, 473.0, 0.004)]
transforms = [Transform(:tf, deg2rad(-70), 0.0, 0.0;
base_pos=[0, 0, 50], base_point=:anchor, rot_point=:mass)]
# Assemble and compile
sys = SystemStructure("pendulum", set; points, segments, transforms)
sam = SymbolicAWEModel(set, sys)
init!(sam)
plot(sam.sys_struct)
# Simulate with live visualization
dt = 0.05
for _ in 1:500
t_start = time()
next_step!(sam; dt)
plot!(sam.sys_struct)
sleep(max(0, dt - (time() - t_start)))
endFor YAML-based model definition, see Building a System using YAML.
Note: The first run will be slow (several minutes) due to compilation. Subsequent runs will be much faster thanks to binary caching.
See the Getting Started Guide for detailed instructions.
StableAWEModels provides the building blocks for assembling kite models from YAML or Julia constructors. Ready-to-use kite models live in dedicated packages:
- RamAirKites.jl — Ram air kite with bridle system, 4-tether steering, and deformable wing groups
- V3Kite.jl — TU Delft V3 leading-edge-inflatable kite, YAML-based configuration
A minimal coupled aero-structural model included in data/2plate_kite/:
using StableAWEModels, VortexStepMethod, GLMakie
using StableAWEModels: Point
using KiteUtils: init!, next_step!
StableAWEModels.copy_data()

set_data_path("data/2plate_kite")

struc_yaml = joinpath(get_data_path(),
    "particle_structural_geometry.yaml")

# Load settings and VSM configuration
set = Settings("system.yaml")
vsm_set = VortexStepMethod.VSMSettings(
    joinpath(get_data_path(), "vsm_settings.yaml");
    data_prefix=false)

# Build system structure from YAML
sys = load_sys_struct_from_yaml(struc_yaml;
    system_name="2plate_kite", set, vsm_set)
sys.segments[:kcu_steering_right].l0 += 0.1
sys.segments[:kcu_steering_left].l0 -= 0.1
sys.winches[:main_winch].brake = true

sam = SymbolicAWEModel(set, sys)
init!(sam; remake=false, lin_vsm=false)
plot(sam.sys_struct)

# Simulate with live visualization
dt = 0.01
for step in 1:1000
    t_start = time()
    next_step!(sam; dt, vsm_interval=1)
    plot!(sam.sys_struct)
    sleep(max(0, dt - (time() - t_start)))
end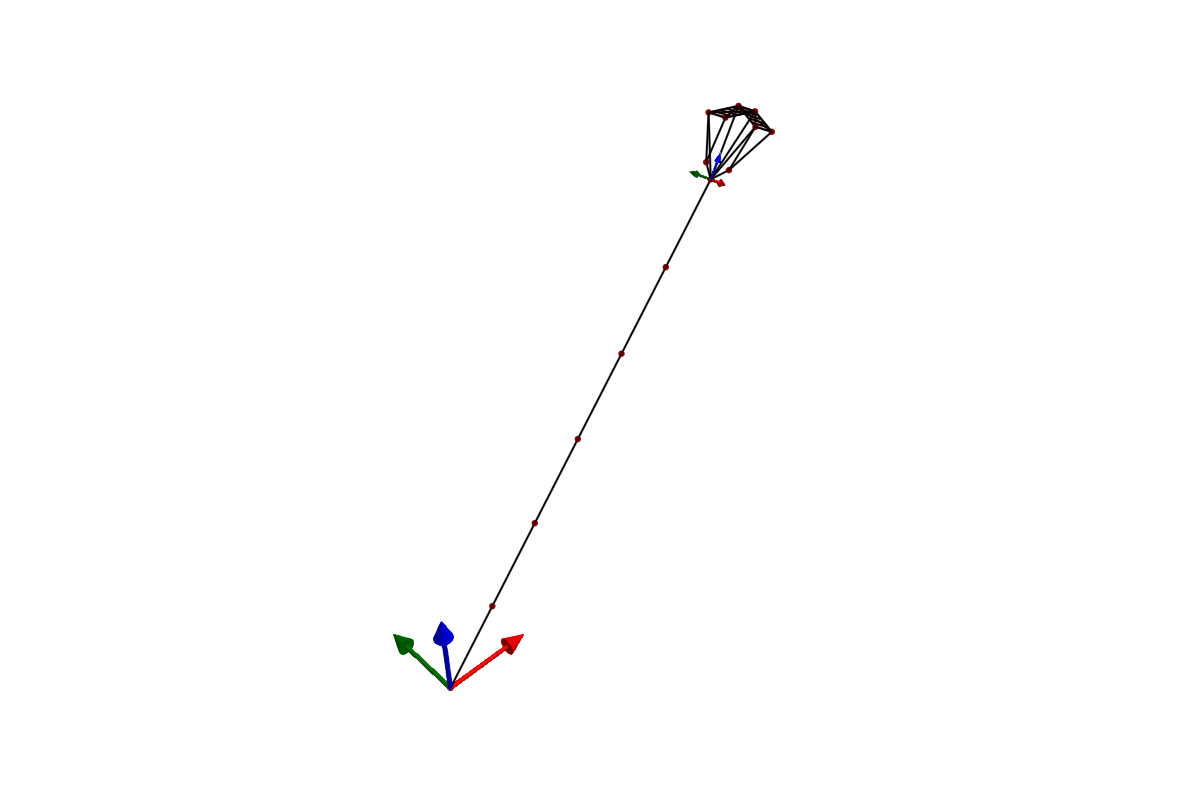
Copy examples to your project and run the interactive menu:
using StableAWEModels
using GLMakie
StableAWEModels.copy_data()
StableAWEModels.copy_examples()
include("examples/menu.jl")
using GLMakie enables the built-in plotting extension.
See the Examples
page for details.
Each component is tested in isolation using minimal models built from constructors, with results verified against analytical solutions. This proves that the underlying dynamics are physically correct — for example, that angular momentum is conserved, that terminal velocity matches the analytical prediction, and that spring-damper forces follow the expected constitutive law.
# Run all tests
julia --project -e 'using Pkg; Pkg.test()'

# Run a specific test file
julia --project test/test_point.jl| Test file | What it verifies |
|---|---|
test_point |
Gravity free-fall, damping, quasi-static equilibrium |
test_segment |
Spring-damper forces, stiffness, drag |
test_wing |
RIGID_DYNAMICS and PARTICLE_DYNAMICS wing construction, VSM coupling |
test_wing_dynamics |
Rigid body torque response, precession, angular momentum |
test_tether_winch |
Reel-out, Coulomb/viscous friction, terminal velocity |
test_pulley |
Equal-tension constraints, multi-segment pulleys |
test_transform |
Spherical coordinate positioning |
test_quaternion_conversions |
Quaternion ↔ rotation matrix |
test_quaternion_auto_groups |
Auto-generated twist DOFs |
test_principal_body_frame |
Principal vs body frame separation |
test_heading_calculation |
Kite heading from tether geometry |
test_section_alignment |
VSM section ↔ structural point mapping |
test_match_aero_sections |
Asymmetric aero/structural section matching, polar interpolation |
test_profile_law |
Atmospheric wind profile verification |
test_bench |
Performance regression tracking |
Key related packages:
- RamAirKite.jl — ram air kite model
- V3Kite.jl — TU Delft V3 kite model
- KiteUtils.jl — shared types and utilities
- VortexStepMethod.jl — aerodynamic solver
- AtmosphericModels.jl — wind profiles
- KiteModels.jl — non-symbolic, predefined kite models
- KiteSimulators.jl — meta-package
- KiteControllers.jl — control algorithms
Visualisation uses the built-in GLMakie extension
(ext/StableAWEModelsMakieExt.jl) — just using GLMakie to enable
plotting.
- Research Fechner — scientific background for winches and tethers
- Submit an issue
- Start a discussion
- Ask on Julia Discourse
- Email Uwe Fechner: uwe.fechner.msc@gmail.com
Authors: Bart van de Lint (bart@vandelint.net) Uwe Fechner (uwe.fechner.msc@gmail.com) Jelle Poland
This project is licensed under the LGPL-3.0 License.
If you use StableAWEModels in your research, please cite this repository:
@misc{SymbolicAWEModels,
  author = {Bart van de Lint, Uwe Fechner, Jelle Poland},
  title = {{SymbolicAWEModels}: Symbolic airborne wind energy system models},
  year = {2025},
  publisher = {GitHub},
  journal = {GitHub repository},
  howpublished = {\url{[https://github.com/OpenSourceAWE/SymbolicAWEModels.jl]}},
}Technische Universiteit Delft hereby disclaims all copyright interest in the package "StableAWEModels.jl" (symbolic models for airborne wind energy systems) written by the Author(s).
Prof.dr. H.G.C. (Henri) Werij, Dean of Aerospace Engineering, Technische Universiteit Delft.
See copyright notices in the source files and the list of authors in AUTHORS.md.