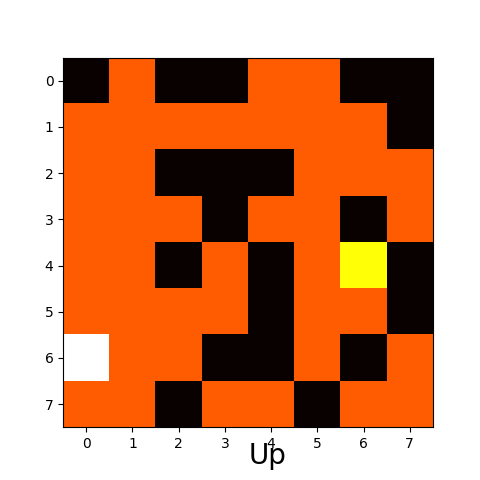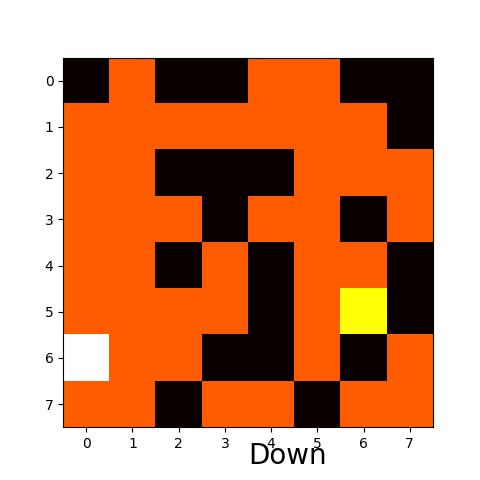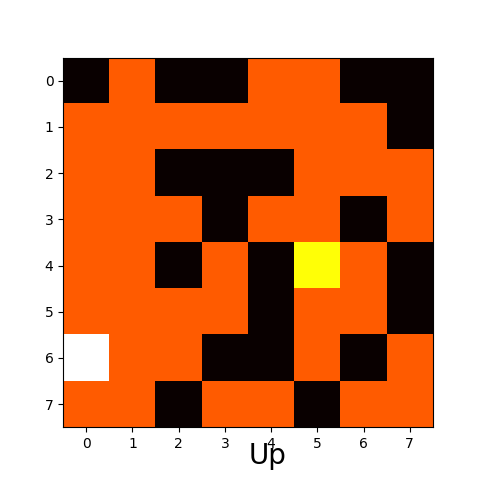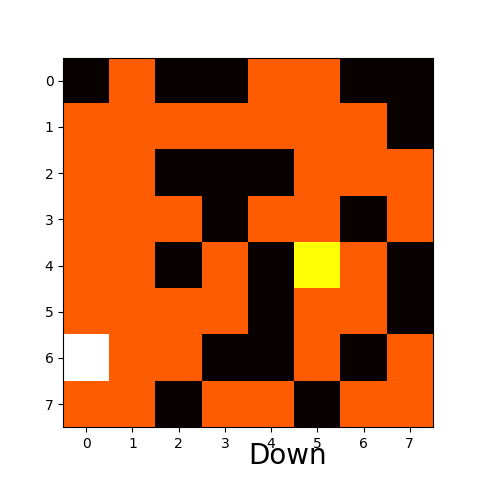Environments for Statistical Reinforcement Learning
pip install statisticalRL-environments
python fulldemo.py
MABS:
    mab-bernoulli
    mab-gaussian
    mab-binomial
    mab-batch-quantized
MDPs:
    random-rich
    ergodic-random-rich
    random-12
    random-small
    random-small-sparse
    random-100
    three-state
    nasty
    river-swim-6
    ergo-river-swim-6
    ergo-river-swim-25
    river-swim-25
GRIDWORLD MDPs:
    grid-random-1616
    grid-random-1212
    grid-random-88
    grid-2-room
    grid-4-room
The library contains several stochastic MDPs, that is for which transition and reward functions are not deterministic.
Furthermore, the library supports random generations of MDPs. The environments containing "random" in their name are randomly generated MDPs, that is with randomly generated transition and reward (stochastic) functions. For reproducibility reasons, they are generated with a given seed.
You can modify them in the registration list "registerStatisticalRLenvironments" available in the init file of lib. In this list, you will find environments registered with specific parameters, including the (last) parameter "seed" which is used to generate the random transition and reward functions.
"random-small" : lambda x: registerRandomMDP(nbStates=3, nbActions=4, maxProportionSupportTransition=0.5, maxProportionSupportReward=0.4, maxProportionSupportStart=0.1, minNonZeroProbability=0.15, minNonZeroReward=0.25, rewardStd=0.1,seed=5),
Note: fixing this seed (here sedd=5) does not prevent the transitions/rewards to be stochastic, as they are using another random number generating process.
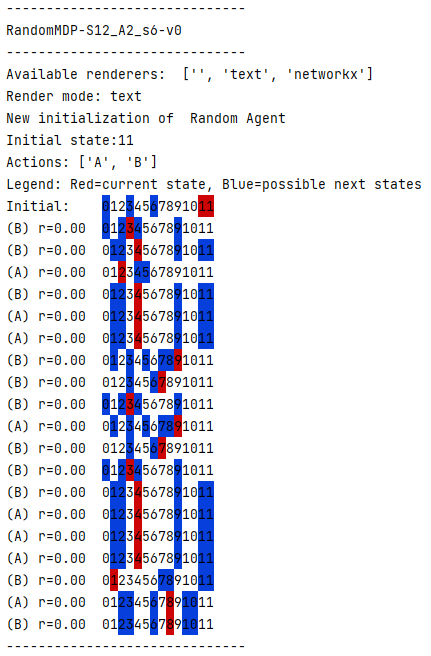
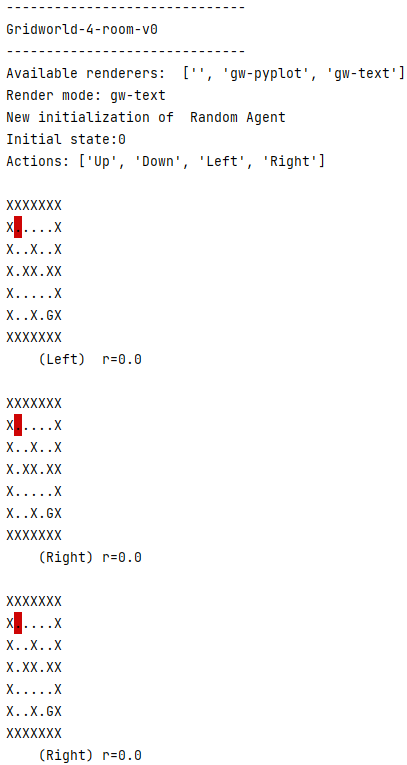
Each type of environment comes with different renderers, including the null renderer that displays nothing.
This rendering is available for all environment types.
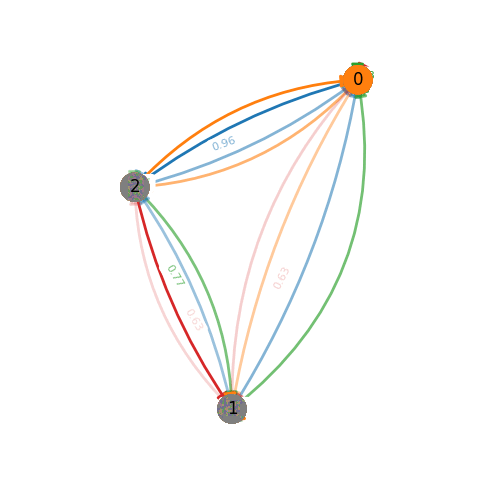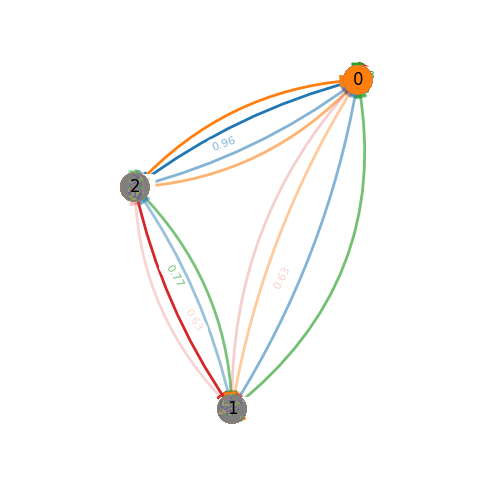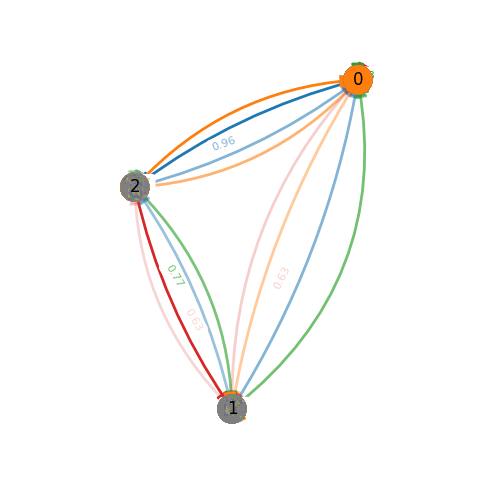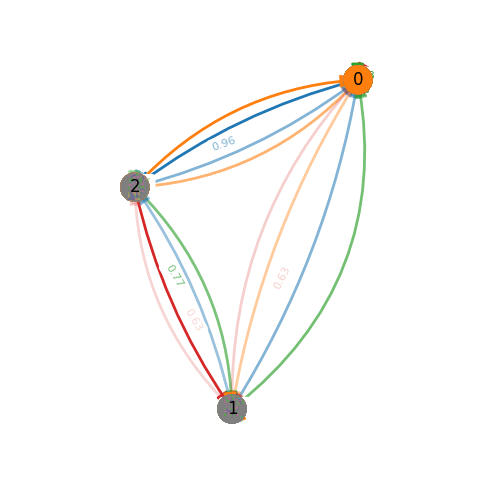
This rendering is available for MDPs. On top of the visual display, it captures a screenshot png at each time step. This may be slow for large MDPs.
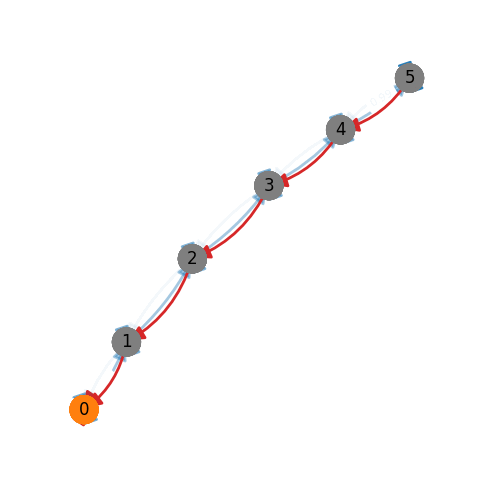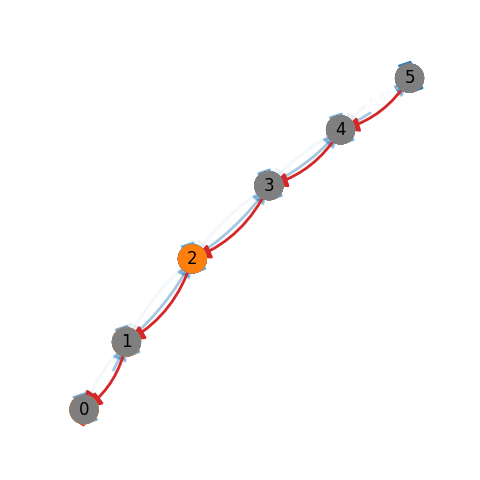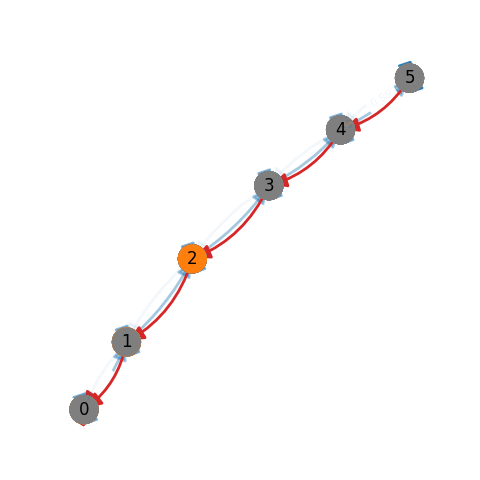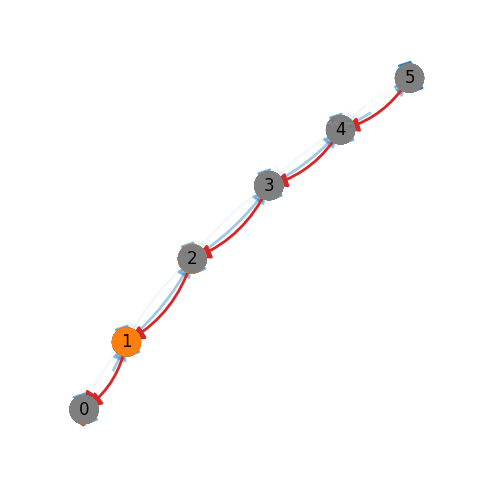
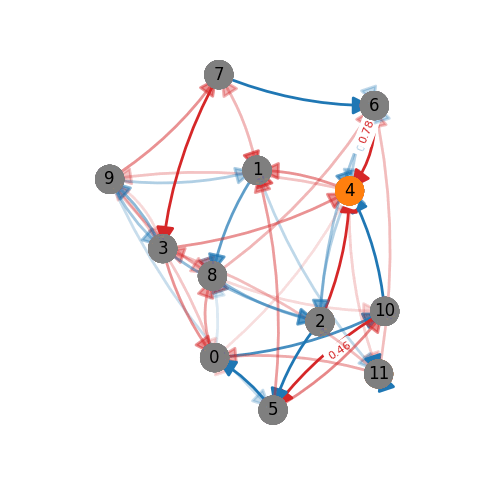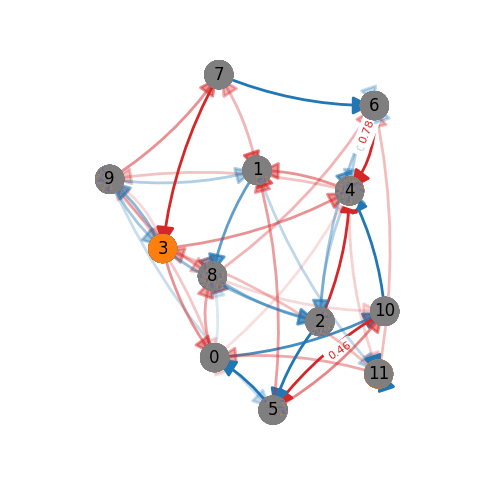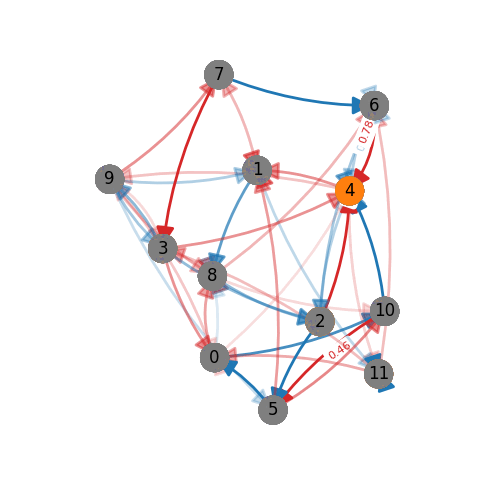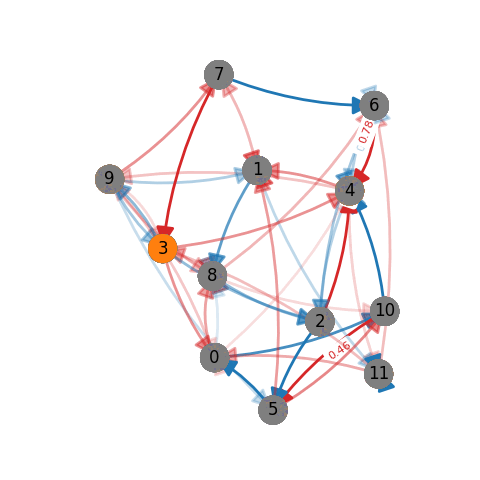
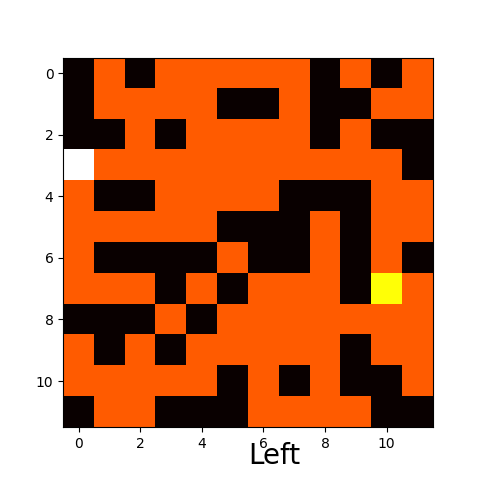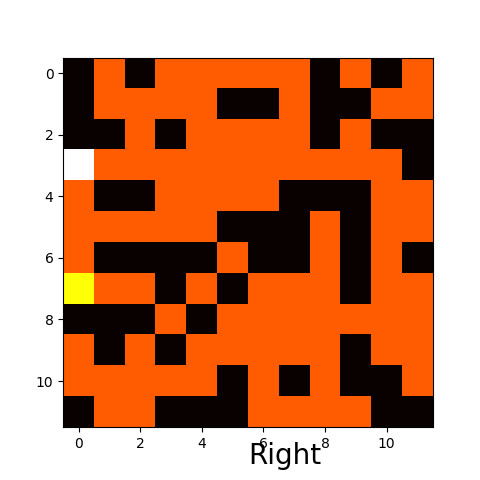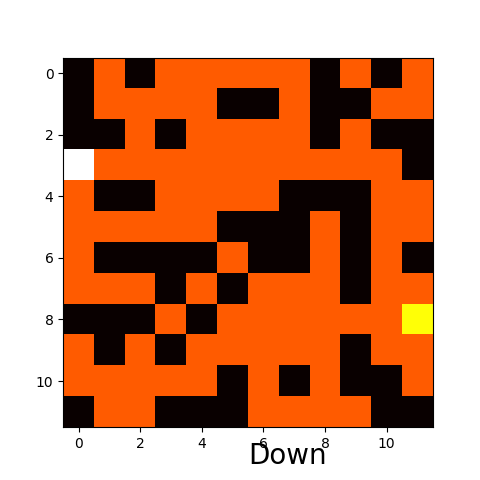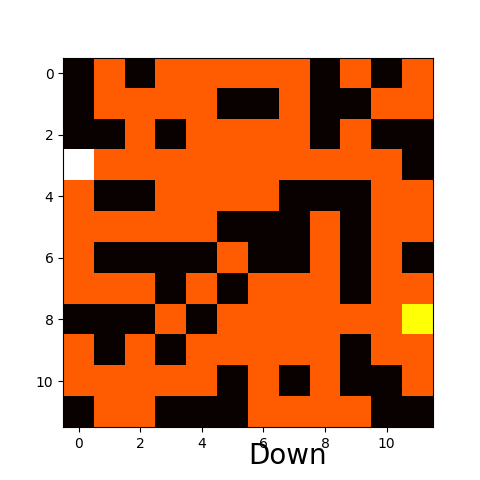
This rendering is available for Gridworld-MDPs. On top of the visual display, it captures a screenshot png at each time step.